Category Archives: VMWorld

Presenting with a Robot – True Hackathon Style!

Every year at the VMware Explore Hackathon in Las Vegas, we kick off the evening with the usual housekeeping. You know the drill: going over the schedule, explaining how solo hackers get matched into teams, running through the hardware prizes, introducing our guest mentors, and explaining how the judging works. Usually, that means standing on stage with a clicker and talking through a slide deck.

This year, I had Kit, my Reachy Mini robot, sitting on my desk. And whilst there are plenty of fun demos you can run with a robotic head, I thought: why should I do all the talking when I have a robot capable of expressive gestures, speech synthesis, and head tracking?

Why not let Kit present the hackathon opening to the room?

It sounded like a brilliant idea on paper. In practice, making a physical robot co-present on a conference stage in front of a live audience requires a lot more than just piping text into a speech model. The robot needs stage presence. It needs to look at the audience, turn its head to glance at the slide on the big projector screen, execute expressive antenna and head motions, and change the slides automatically at the right moment.

So we built reachy-mini-presenter, an open source presentation app for Reachy Mini. Here is how it came together, what made it work, and what we learned when taking a robot on stage.

See Kit in Action at the Hackathon

Before getting into the code and architecture, here is the live video of Kit co-presenting the hackathon kickoff at VMware Explore 2026:

Hearing a tiny robot announce to a ballroom full of developers that it was my virtual robotic slave, introduce Bob Plankers, warn everyone that they will be judged, and hand back to its human overlord set exactly the right tone for the evening.

What It Takes to Share a Stage With a Robot

Giving a speech through a robot is easy if you do not care how it looks. You send an audio stream to a speaker and let the robot sit there motionless. But that completely defeats the point of using an embodied robot.

To feel like a genuine co-presenter on stage, the system had to solve four key problems:

  • Keep the slides on the big screen in lockstep with the spoken audio without requiring a human to hit a clicker.
  • Synchronise physical head gaze and antenna emotions to the exact words being spoken.
  • Fit naturally into standard presentation workflows so anyone can write or edit a deck in Google Slides, PowerPoint, or Markdown.
  • Run reliably in a convention centre environment where venue Wi-Fi is notoriously unpredictable.

If any of those pieces fail, the illusion breaks immediately.

The Speaker Notes Are the Script

The biggest breakthrough in the design was deciding where the robot directives should live. We did not want a complex external timeline editor or a custom visual choreography tool. Presenters already write their scripts in speaker notes.

So we turned speaker notes into a stage script by supporting inline directives. You write your normal notes, and sprinkle in robot commands using brackets:
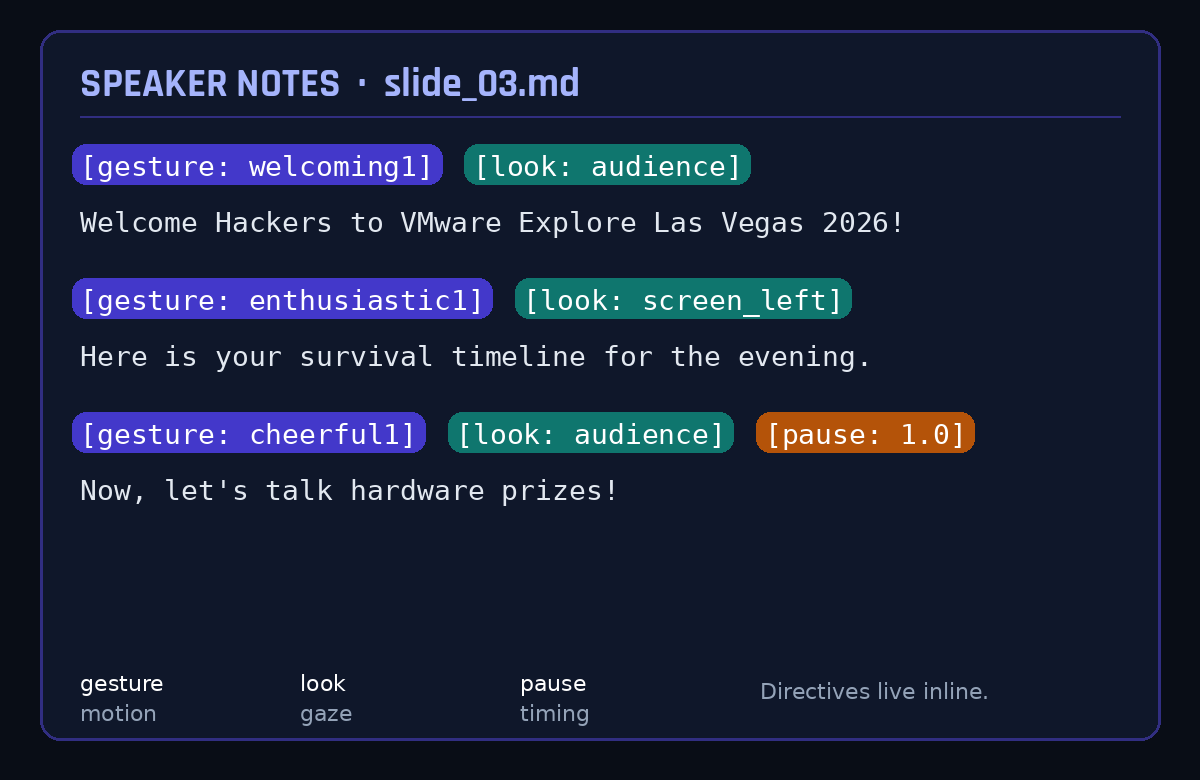
The parser extracts these directives on the fly:

  • Gaze orientations orient the robot head dynamically toward the audience or the presentation screen.
  • Expressive motion gestures trigger Pollen Robotics recorded move trajectories.
  • Timing pauses let the robot wait for audience laughter or applause before resuming speech.
  • Head wobbles and antenna drift run continuously during speech to mimic natural human speaking cadences.

When Kit referenced the timeline slide on the projector, it turned its head toward the screen on its left, delivered the line, and then turned back to face the audience. That single behaviour transformed it from a talking speaker into a presenter.

Under the Hood: Three Pieces, One Show

The application runs as a local FastAPI service that integrates natively into the Reachy Mini desktop application ecosystem.
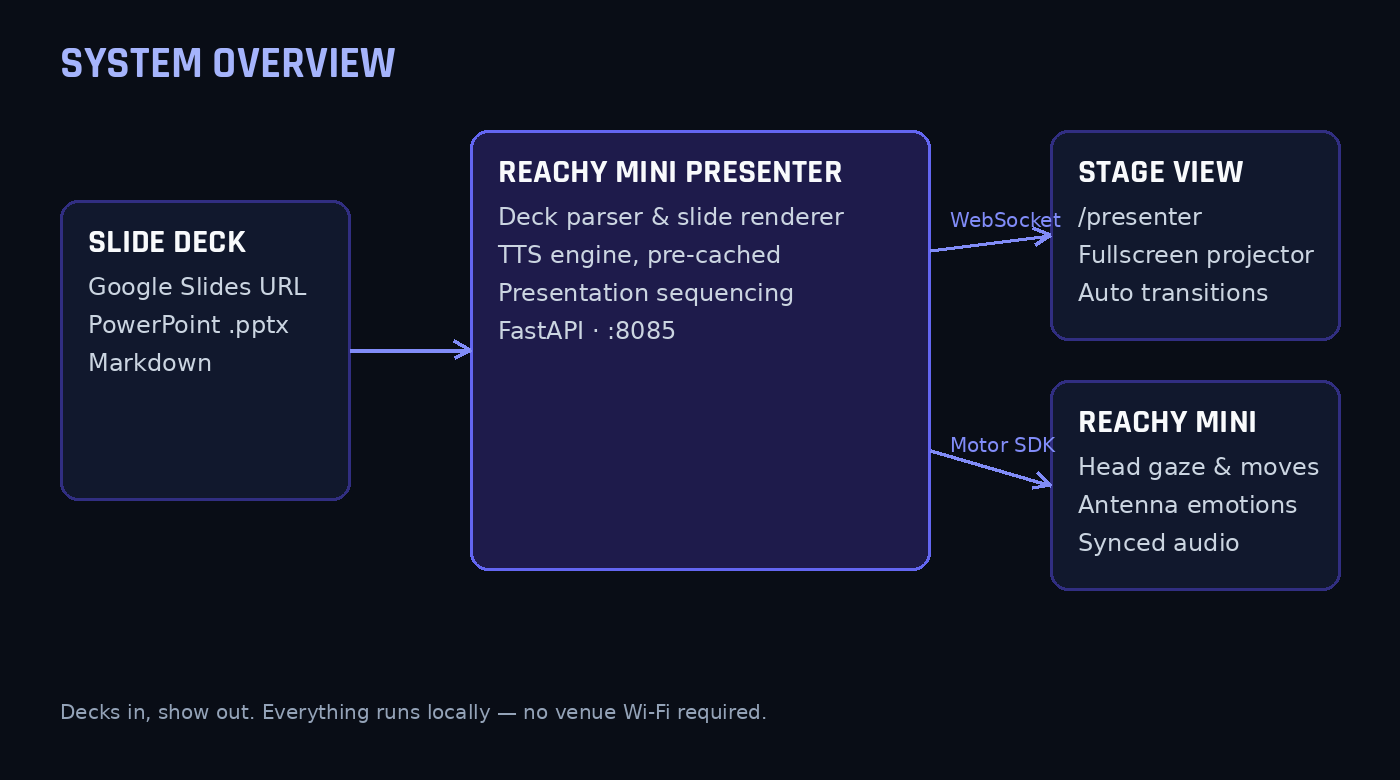
The design separates presentation into two browser views:

  • The presentation stage view at slash presenter is projected onto the conference hall screens, showing high-resolution rendered slide graphics that transition automatically via WebSockets.
  • The control dashboard view at the root URL runs on the operator laptop, providing slide thumbnails, live speaker note previews, playback controls, and manual gesture triggers.

For deck ingestion, we built support for Google Slides, PowerPoint files, and Markdown. For Google Slides, you simply paste the presentation share link into the dashboard. The app fetches the deck, parses the shapes and notes, renders high-resolution slide images using LibreOffice or Keynote CLI, and caches everything locally.

The Golden Rule: Never Trust Venue Wi-Fi

If you take only one lesson away from this post, let it be this: never rely on real-time cloud text-to-speech during a live stage presentation.

Conference Wi-Fi in a room packed with hundreds of engineers is always a gamble. If an API call stutters or drops packets, the robot freezes mid-sentence, the slide does not advance, and everyone stares at an awkward silent robot.

To avoid this, reachy-mini-presenter pre-renders and caches every spoken phrase locally as WAV files before the presentation starts. We supported local neural voices via Kokoro and Edge TTS, along with cross-platform native audio playback engines:

  • macOS uses the native afplay utility.
  • Windows uses the low-level Windows multimedia MCI sound subsystem.
  • Linux uses ffplay or mplayer.

Because the entire audio pipeline is cached locally on the laptop before walking onto the stage, the presentation runs with zero network dependency during the actual talk.

Stage Fright: Notes From a Live Robot

Putting hardware on stage always delivers a few surprises. Here is what we had to debug:

  • Audio levels in an exhibition hall need serious headroom because a desk speaker that sounds loud in an office is virtually inaudible in a hall with several hundred people talking. We ended up with a strategicly placed mic hooked directly into the venue sound system.
  • Motor kinematics limits triggered warnings during fast transitions when moving between an extreme look-up pose and an enthusiastic celebration gesture in one frame, which we smoothed out with easing curves.
  • Comic timing requires deliberate pause directives because in early dry runs the robot steamrolled straight through punchlines without waiting for the room to laugh. Inserting explicit one-second and two-second pause directives after jokes allowed room for audience reaction before the next slide loaded.

Your Turn: Run It Yourself

The best part about the Reachy Mini ecosystem is that you do not need to clone git repositories or mess around in a terminal to get this working.

If you have a Reachy Mini, you can install and run the app with one click directly inside the official Reachy Mini Control desktop app. Open the app catalog in Reachy Mini Control, search for Reachy Mini Presenter, and hit install. It downloads into the robot app environment and launches right from your dashboard.
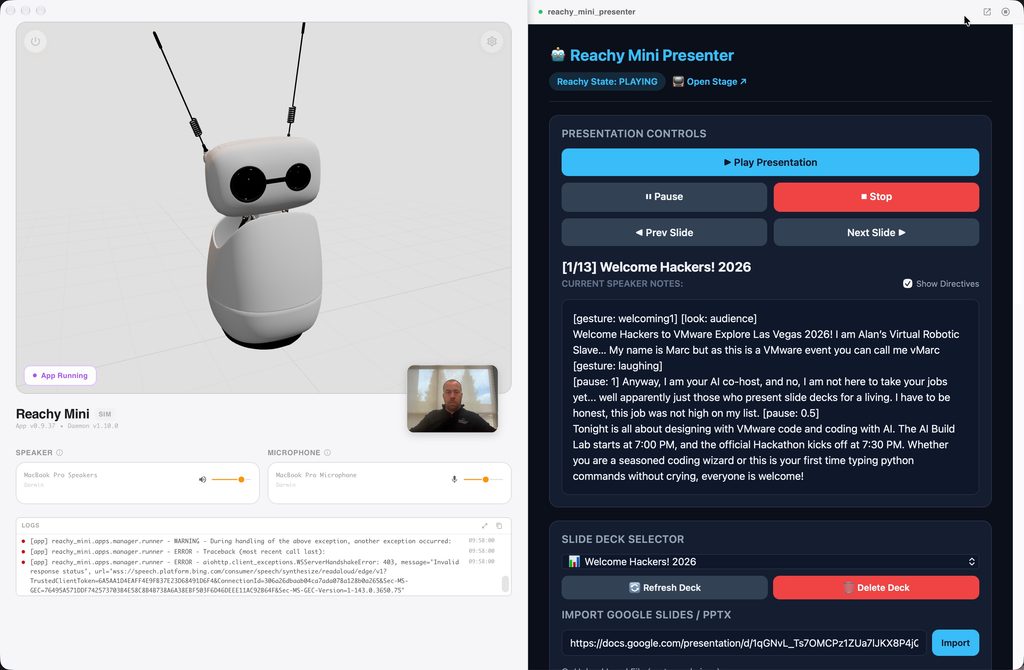
I also created a dedicated website for the project on Hugging Face Spaces:

Reachy Mini Presenter on Hugging Face

The site includes an interactive preview showing how the robot moves and reacts to slide directives, a full reference for speaker note tags, and a catalog of supported gestures.

Once you launch the app, you will have two interfaces ready to go:

  • The control dashboard at http://localhost:8085/ lets you load decks, review speaker notes, and drive the presentation.
  • The presentation stage at http://localhost:8085/presenter goes onto a projector or secondary display to show fullscreen slides that advance automatically in sync with the robot.

If you want to poke around under the hood, tweak the Python code, or add custom animations, the source code is completely open on the Hugging Face Space repository as well.

Wrapping Up

Building reachy-mini-presenter was one of the most rewarding robotics projects I have worked on recently. It took Kit from being an interesting desk gadget to an active, helpful participant in a major community event. The reaction from the room at VMware Explore was incredible, and seeing developers laugh and cheer as a robot explained hackathon rules made all the late-night motor tuning completely worth it.

Give it a spin with your own slide decks, experiment with the speaker note directives, and let me know what you build!

The hackathon overall was a great success and always one of my favourite sessions at VMware Explore, thanks to everyone who attended and the winners of prizes, some awesome innovations were created as always!

Tech Confessions at VMworld BCN 2017

This year I was introduced to a new show put together by Amy Lewis from http://commsninja.com/ and her team called Tech Confessions or as I like to call it “Bedside confessions of a geek”, unofficially of course!

In this show I was able to relax on the comfy couch while Amy quizzed me on how i got started with virtualization, there was something about that couch that made me very relaxed as I think I took Amy pretty much through my entire career up to the point where I made it on stage with Pat during the VMworld 2017 Barcelona conference.

I was proud to be the first of many to share their bedside confessions so make sure you subscribe to the youtube channel or the podcast to keep up to date with other people sharing their software defined experiences.

Ways to Watch/Listen

You can subscribe to the podcast here, check out the Tech Confessions website here or Follow their Youtube channel here

For now, here is my video to keep you going….

VMworld VMware Code Hackathon to hit Barcelona 2016

NUCs.jpgOne of my most memorable and enjoyable times this year at
VMworld USA was the Hackathon, basically 5 teams of developers and scripters, who had mainly never met each other before were formed and took part in a Hackathon organized by myself, William Lam and the VMware Code team.  These dedicated coders gave up free vendor meals and alcohol (OK well maybe we provided both as well) to essentially come code with us on 5 Intel NUC units we had pre-built with vCenter/ESX and VSAN.

The people who were involved ranged from people just learning to coding ninjas and API experts, that’s what I loved, seeing these people learning and working together was truly awesome!

What was involved?

The 5 teams each individually worked on a project which they had come up with and registered before the event, they ended up producing 5 individual projects which were judged and a winning team was selected.

The projects will soon all be available on github or commits to existing projects so the entire VMware community can benefit.

The projects were varied throughout the VMware product range and are listed below:

  • Team 1 – Worked on a project which provided community health check against the vSphere platform (vCheck Enhancements)
  • Team 2 – Worked on Autoscaling Groups for vSphere
  • Team 3 – Worked on writing vSphere DSC resources for Configuration Management
  • Team 4 – Worked on Visualizing Ops: VMware Telemetry with Snap and Grafana
  • Team 5 – Worked on Using Test Driven Development to validate NSX

I know everyone who attended thoroughly enjoyed the event whether they were part of a team or just turned up to spectate, drink, eat and heckle. Continue reading →

VMworld 2015–San Francisco–PowerCLI Session

Firstly, I want to say I had a blast at VMworld SFO this year, it was a fantastic show and it really felt like everyone was buzzing with excitement and interest in VMware, the announcements, the partners and just about everything else that was going on.  I think this may be one of my favorite years to date.


On top of the general excitement there was of course the awesome group discussions, meet the experts, sessions and customer meetings which I took part in, I was lucky enough to present on some awesome topics this year, the normal PowerCLI deep dive I give with Luc (see below) and also a fantastic new technology called Instant Clone (AKA VMfork). The instant clone presentation is not yet available but for those who are into PowerCLI I wanted to let you know that Luc and my session was made available for everyone to view via PowerCLI, including the information we gave on best practices and also a technical preview of PowerCLI.


If you are going to VMworld Barcelona do not worry, we are already adjusting our session to be even better with more best practices and even more information on the awesomeness of PowerCLI.  Well worth attending and watching this as well.


Automating Tags and Tag Category creation and assignment with PowerCLI

Fimageor a couple of releases now PowerCLI has been able to work with vSphere Tags, A tag is a label that you can apply to objects in the vSphere inventory.

After creating a tag, you can assign that tag to a category. Categories allow you to group related tags together. When you define a category, you can also specify the type of objects to which its tags can be applied to and whether more than one tag in the category can be applied to an object.

For example, if you want to tag your virtual machines by the owner, you can create a category called “Owner” and specify that it applies to virtual machines only and that only a single tag can be applied to a virtual machine at any time. The tags in this category could be Alan, John or Fred etc.

I have had a few people ask me how they can use PowerCLI to work with external systems, CMDBs, databases or even just a CSV file.

One example of this is where a company could have various information about hosts or datastores or virtual machines, like the project that purchased these, a cost code or an owner.  This data is generally stored somewhere else but it would be great to see this information straight in the vSphere Web Client where you manage the objects so that you can instantly contact the owner or work out which project the object is being used for etc.

The below video shows how we can use PowerCLI and this generic script I created to import the data, create the tags and tag categories and assign them to the machines, it uses a csv as input but this could obviously be changed to anything which can be read in PowerShell, like a API, database, application etc etc.

Automating tags and tag categories video

Example Script

This script is the script I created as an example which relates each of the items in the Name column to an object in the inventory then for each of the other column headers it will create a category and then the tags that are under the categories, once this has been done it will apply the tags to the objects in the Name column.

Connect-viserver myvc.corp.local -user administrator@vsphere.local -pass Pa$$w0rd
$CMDBInfo = Import-CSV C:\Software\cmdbinfo.csv

# Get the header names to use as tag category names
$TagCatNames = $cmdbinfo | Get-Member | Where {$_.MemberType -eq "NoteProperty"} | Select -Expand Name

# Create the Tag Category if it doesnt exist
Foreach ($Name in ($TagCatNames | Where {$_ -ne "Name"})) {
    if (-Not (Get-TagCategory $Name -ea SilentlyContinue)) {
        Write-Host "Creating Tag Category $Name"
        New-TagCategory -Name $Name -Description "$Name from CMDB" | Out-Null
        
        # Create Tags under the Tag Categories
        $UniqueTags = $cmdbinfo | Select -expand $name | Get-Unique
        Foreach ($Tag in $UniqueTags) {
            if (-Not (Get-Tag $Tag -ea SilentlyContinue)) {
                Write-Host "..Creating Tag under $Name of $Tag"
                New-Tag -Name $Tag -Category $name -Description "$Tag from CMDB" | Out-Null
            }
            # Assign the Tags to the VMs/Hosts
            $cmdbinfo | Where {$_.($Name) -eq $Tag} | Foreach {
                Write-Host ".... Assigning $Tag in Category of $Name to $($_.Name)"
                $TagAssignment = Get-Tag -Category $Name -name $Tag
                New-TagAssignment -entity $($_.Name) -Tag $Tagassignment | Out-Null
            }
        }          
    }
}

Automation–its not just a tick box!

During VMworld 2013 I presented together with Thomas Corfmat a session entitled “Automating the Software Defined Datacenter, How do I get started?” this was meant as a introduction on how someone who was interested in automation could start with VMware products and what they could achieve.

One of the first things we mentioned in this session is that there is no one size fits all, there isn’t one tick box that you can click and then suddenly “enable automation”, this is a common misconception by the C-Level staff of many organizations as they see automation in a slide deck and want some of it!  Automation is actually a combination of products, workflows and scripts created to give you the specific results you need.

Continue reading →

PowerCLI Group Discussion

VMworld PowerCLI Group Discussion–Part 3–Launching and Using

image

Following on from the previous posts in this series, this post will take us through the group discussion held at VMworld this year and expand on the items noted during the session.

This post will focus on what people in the session used PowerCLI for and also the various ways people used to launch the scripts.

Continue reading →

PowerCLI Group Discussion

VMworld PowerCLI Group Discussion–Part 2–Resources

ResourcesFollowing Part 1 of these posts where we discussed getting started in PowerCLI I now give you Part 2 of the note taking by Nigel Boulton at VMworld in the PowerCLI Group Discussion.

In this part of the session we discussed what resources were available to people using PowerCLI.

As with the previous post I will expand on the notes taken and give you the complete list below.

If you have more resources make sure you add a comment and share them with others.

Continue reading →